CNC Lathe Tending for Stainless Steel Liquid-Cooling Connectors
Automation outline for turning stainless steel liquid-cooling connectors: pallet feeding, robot chuck loading, automatic unloading and finished-part store management.
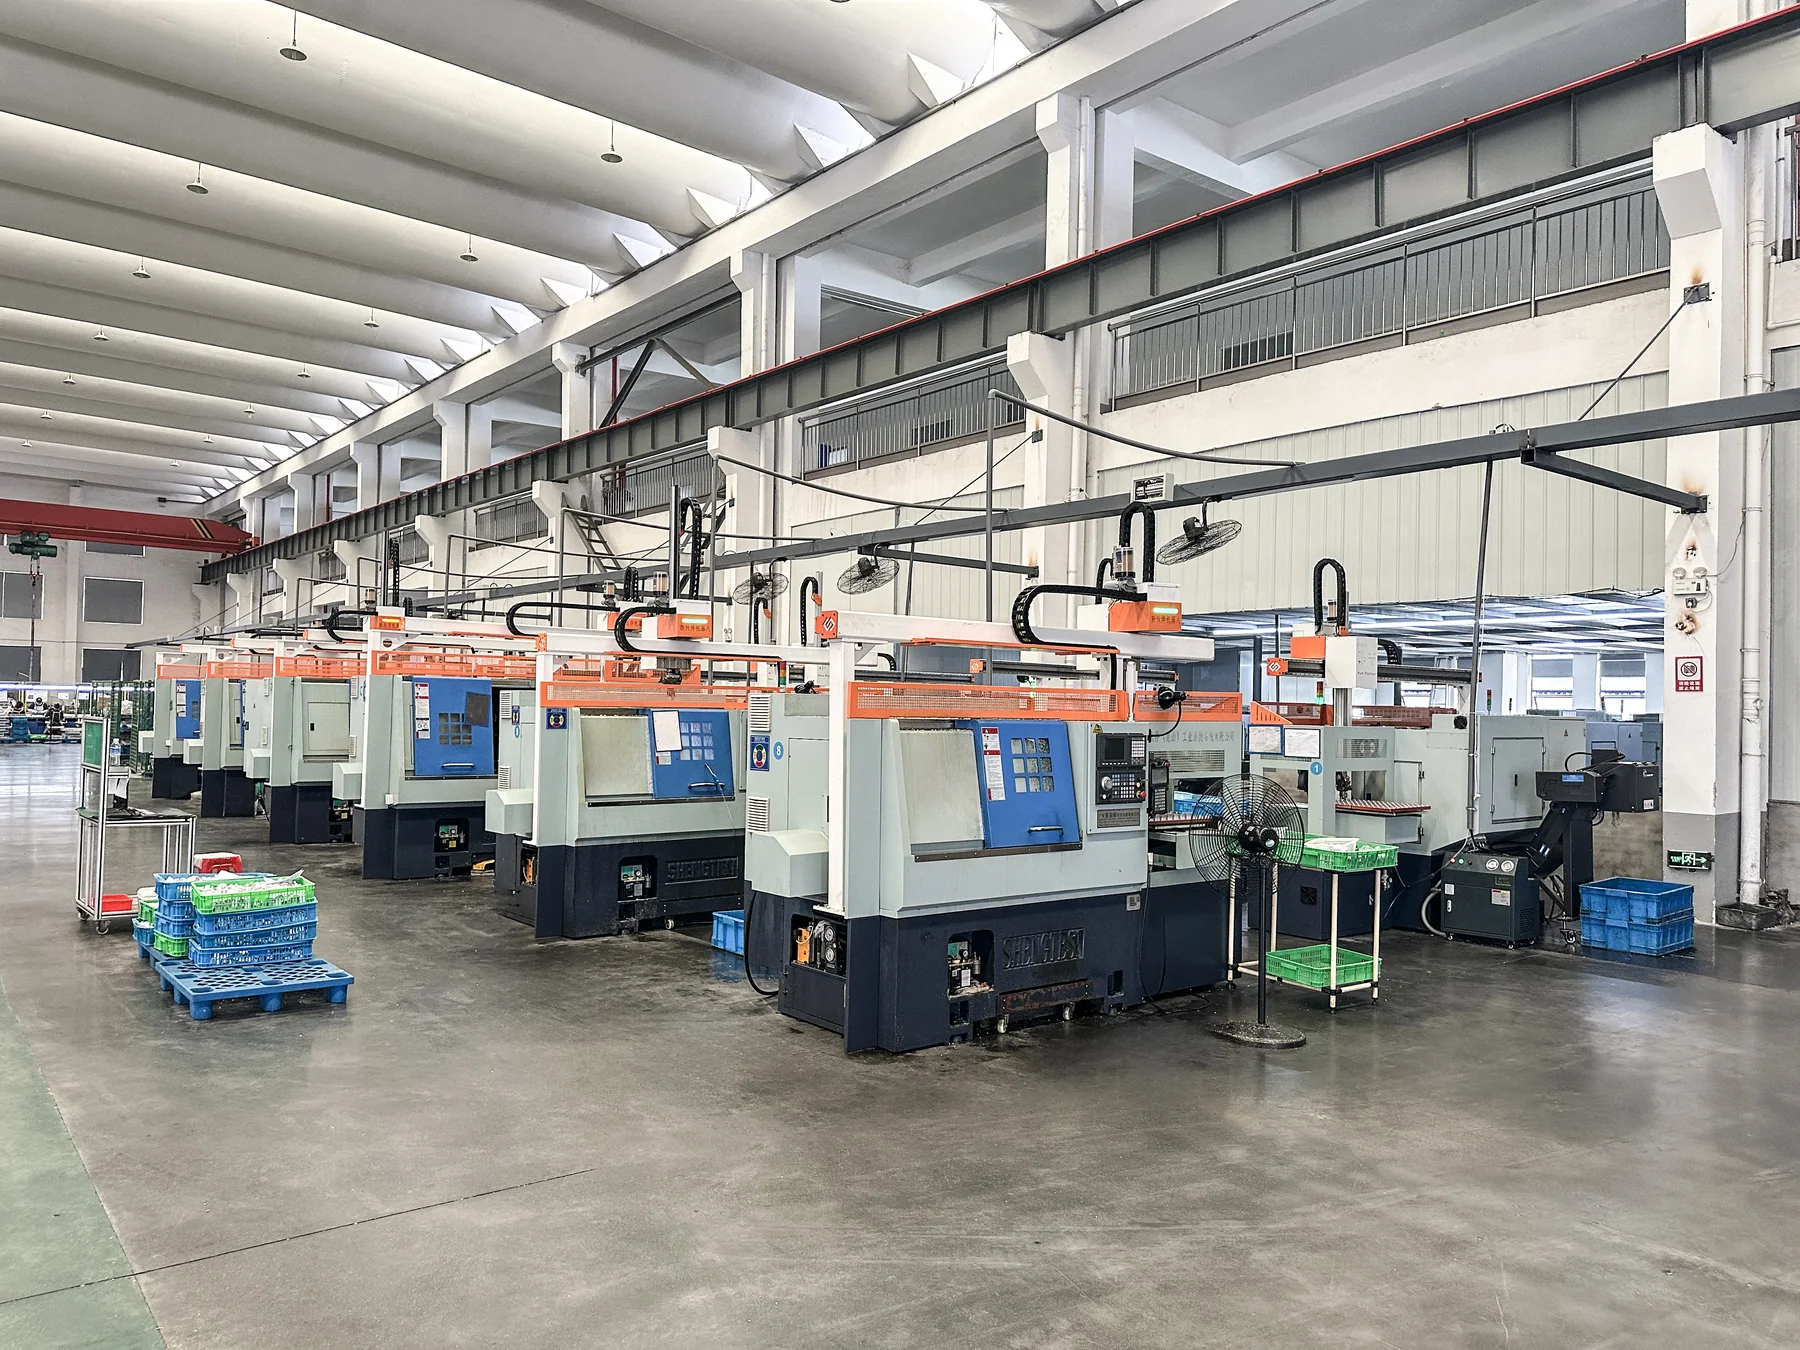
CNC Lathe Tending for Stainless Steel Liquid-Cooling Connectors
Connectors carry threads, sealing faces and locating features. In turning, the part must reach the chuck consistently and be clamped with confirmation, in an environment of coolant and swarf.
1. Overview
Liquid-cooling connectors join lines or equipment in a cooling loop and normally include an interface structure with threads, sealing faces and locating features. This project addresses stainless steel blanks machined on CNC lathes: pallet feeding, robot loading and unloading, machining and finished-part recovery reduce repeated manual handling. The design is based on the real blank geometry and the lathe clamping method, and coordinates robot gripping, chuck clamping, the machining-complete signal and part removal.
2. Production background and retrofit need
- Stainless connector blanks must be gripped securely and placed accurately in the chuck or a dedicated fixture.
- Specifications differ in outside diameter, length and interface structure.
- Threads, end faces and sealing areas must not be damaged.
- Coolant and swarf are present, so the gripper and robot need protection.
- If both ends are machined or the part is clamped more than once, flipping and transfer must be planned.
- On a multi-lathe line the robot service order and each machine's completion state must be coordinated.
The source material does not describe how the part was produced before automation; that still requires a site record.
3. Workpiece and operation characteristics
What the source material records:
- The workpiece is a stainless steel liquid-cooling connector machined from an individual blank (the material class is recorded; the grade is not).
- A connector may involve threads, sealing faces, locating features and a metal blank of varying geometry.
- Coolant and metal swarf are present in the machining environment.
Business confirmation (21 Oct 2026)
- Workpiece material: stainless steel (business confirmation; the grade is still to be confirmed).
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Stainless grade — not recorded; do not infer from industry practice
- Specification range (outside diameter / length) and part weight
- Blank form (bar-cut, forged or other)
- Chuck or dedicated fixture type and clamping method
- Position of the grip area relative to threads and sealing faces
- Whether both ends are machined and whether flipping is needed
4. Automation challenges
- Locating and clamp confirmation in the chuck, including the auto door, machining-complete signal and motion interlock.
- Grip reliability in a coolant and swarf environment.
- Protecting threads and sealing faces during pick, transfer and storage.
- Flipping and second clamping for two-ended work.
- Fixture and pallet compatibility, changeover and poka-yoke across specifications.
5. System design
- Pallet feeding — stainless blanks are placed in a fixed orientation so pick position and attitude are as specified.
- Robot pick — the gripper or dedicated fixture is selected from blank size, weight and grip area.
- Automatic lathe loading — the part enters the chuck or fixture and loading is confirmed by part-present and clamp signals.
- Machining-state handshake — the part is removed only after machining is complete and the machine permits unloading.
- Multi-operation work — parts needing a second clamping or another operation follow the actual routing; single-operation parts go straight to finished recovery.
- Finished-store management — connectors are placed in a defined orientation to avoid collisions with threads and sealing areas.
6. Loading and unloading sequence
- Pallet → robot pick → into the chuck or dedicated fixture
- Part-present and clamp confirmed → turning → machining complete and unloading permitted
- Robot unloads → finished parts stored by orientation → next cycle
7. Machine, robot and storage coordination
What the proposal requires of the cell — design requirements, not measured behaviour:
- Auto door, chuck clamp state, machining-complete signal and robot motion must be interlocked.
- The implementation depends on the machine model and control system.
- On a multi-lathe line, robot service order and each machine's completion state must be coordinated.
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Chuck type (hydraulic / pneumatic) and how the clamp signal is taken
- Auto-door control and the release condition
- PLC-to-machine communication method
- Pause and manual-intervention procedure for grip failure, dropped parts and alarms
8. Key selection basis
The proposal only states that the gripper or dedicated fixture is selected from blank size, weight and grip area; no gripper type or robot model is fixed. It also notes that whether the machine has a suitable automation interface is a precondition for robot tending.
Business confirmation (21 Oct 2026)
- Automation configuration: 6-axis industrial robots combined with gantry robots (business confirmation).
- Which machines and operations each type serves is decided by the machine layout; the split is still to be confirmed.
Business confirmation (21 Oct 2026)
- Gripping and locating: determined per workpiece and operation from the part geometry, the available grip area and the faces that must be protected — no single gripper type is standardised across this batch (business confirmation).
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Reach, payload and work-envelope calculation
- Gripper type (parallel two-jaw / three-jaw / soft jaw / dedicated fixture)
- Gripper and robot protection in a coolant environment
9. Machine make and model fit
Business confirmation (21 Oct 2026)
- Machine makes: Shenyang Machine Tool and Yamazaki Mazak (business confirmation).
- Machine models and the number of machines, including the one-to-N configuration, are still to be confirmed.
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Lathe models and number of machines
- Control system type and whether an automation interface is available
- Chuck or dedicated fixture structure and loading aperture
- Whether a second-operation machine is needed for the other end
- Interlock conditions and the retrofit boundary
10. Part storage and automatic feeding
What the proposal records about feeding:
- Pallet-based blank feeding combined with finished-part pallets or a finished store.
- Parts are oriented so the pick position and attitude are repeatable.
- Planning condition: 300 blanks with a target of 8 hours of continuous running (a planning condition, not an acceptance result).
Business confirmation (21 Oct 2026)
- Part storage: 8 tiers × 32 positions = 256 part positions (business confirmation).
- Whether reloading is manual or automatic is still to be confirmed.
Note: the proposal quotes 300 blanks while the confirmed store holds 256 positions; the two figures are not on the same basis and still need to be reconciled.
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Positions per pallet and how the 256 positions are allocated between blank and finished parts
- Support and anti-deformation structure for the pallet
- Manual or automatic reloading, and the reload interval
- Handling of blank shortage, full store and reject parts
11. Multi-machine line (where applicable)
For multi-lathe operation the proposal gives an organisational requirement — coordinating service order and completion state — but does not record how many lathes are connected or what the line configuration is; single-machine and multi-machine configurations are described side by side.
To be confirmed — not recorded in the available material; left blank rather than estimated.
- Whether the cell is single-machine or multi-lathe
- If multi-lathe: number, type and part routing
- Whether a buffer station sits between machines
- Cycle coordination and waiting strategy
- Whether a single machine may run independently after a fault
12. Control, safety and exception handling
Control and safety requirements stated in the proposal:
- Part-present and clamp confirmation participate in the loading decision.
- Parts are removed only after machining is complete and unloading is permitted.
- Coolant and swarf effects on the gripper and robot must be considered.
To be confirmed — not recorded in the available material; left blank rather than estimated.
- I/O list covering state confirmation and action sequence
- PLC make, communication protocol and signal naming
- Fencing, safety door locks and light curtains
- Grip confirmation and part-presence sensing method
- State confirmation after power loss and the reset routine
13. Commissioning and verification
Verification items listed in the proposal — proposed at concept stage; no acceptance record exists:
- Pick and clamping stability
- Repeat locating accuracy when clamping in the chuck
- Finished-surface protection for threads and sealing faces
- Grip reliability under coolant and swarf
- Measured cycle time and continuous-run data
- Changeover and poka-yoke across specifications
The proposal states that cycle time, first-pass yield and operator savings are to be taken from the site record of the actual project.
14. Results and data scope
The proposal gives 300 blanks over a target of 8 continuous hours, i.e. an average blank consumption rate of 37.5 parts per hour, or about 96 s per part. It states explicitly that this is a planning calculation, that it does not represent the machining cycle time, and that an 8-hour unattended run has not been validated.
Single-part machining cycle time is 68 s (business confirmation). The line output interval is not provided. The figures below describe an average consumption rate across a line, which is not the cycle time of a single lathe.
Business confirmation (21 Oct 2026)
- Single-part machining cycle time: 68 s (business confirmation).
- Line output interval, uninterrupted runtime and acceptance conclusions: no record supplied.
| Item | Status for this project |
|---|---|
| A Machine runtime (per shift / per day) | Not provided in the source material (only an 8-hour planning target) |
| B Uninterrupted unattended runtime | Not provided; the source states it still has to be validated on site |
| C Runtime per loading | Proposal text: 300 blanks for 8 hours (planning condition). Confirmed store: 8 tiers × 32 positions = 256 part positions. The two figures are not on the same basis and still need to be reconciled |
| D Single-part cycle time | 68 s per part (business confirmation). Line output interval not provided. The ~96 s average interval across a line is a planning calculation, not a machining cycle |
| E Shift pattern | Not provided in the source material |
| F Project stage | Delivered (business confirmation, 21 Oct 2026); no acceptance report or continuous-run record has been supplied |
15. Scope and limitations
- The concept brings blank pick, lathe clamping, unloading and finished-part collection into a consistent flow, standardises locating and clamp confirmation at the chuck, and provides a basis for connecting further lathes or retrofitting similar connectors.
- Delivered, but without a written record: pick and clamping stability, chuck repeatability, finished-surface protection, measured cycle time and continuous-run data.
- Not provided in the source material: customer name, acceptance records, thread accuracy and pressure-test data. The source states that thread accuracy, sealing performance and pressure resistance must still be produced and inspected to the product requirement and cannot be inferred from automatic tending alone.
16. FAQ
Q: Is robot tending suitable for stainless liquid-cooling connectors?
A: Where blank specifications are stable, the grip position is defined, the fixture is compatible and the machine has an automation interface, robot tending can be evaluated.
Q: How does the robot work with a CNC lathe?
A: It normally requires coordination of the auto door, chuck clamp state, machining-complete signal and robot motion interlock. The implementation depends on the machine model and control system.
Q: Does automatic tending guarantee a leak-free connector?
A: No. Leak performance depends on the sealing design, machining quality, assembly process and the corresponding test.
Q: Can different connector models share one system?
A: Gripper, pallet, fixture and program compatibility must be confirmed, with part identification and changeover poka-yoke in place.
Q: What is the machining cycle time?
A: 68 s per part for a single machining cycle, confirmed by the business. The line output interval depends on the number of lathes and the operation split, which are still to be confirmed.
Reference images
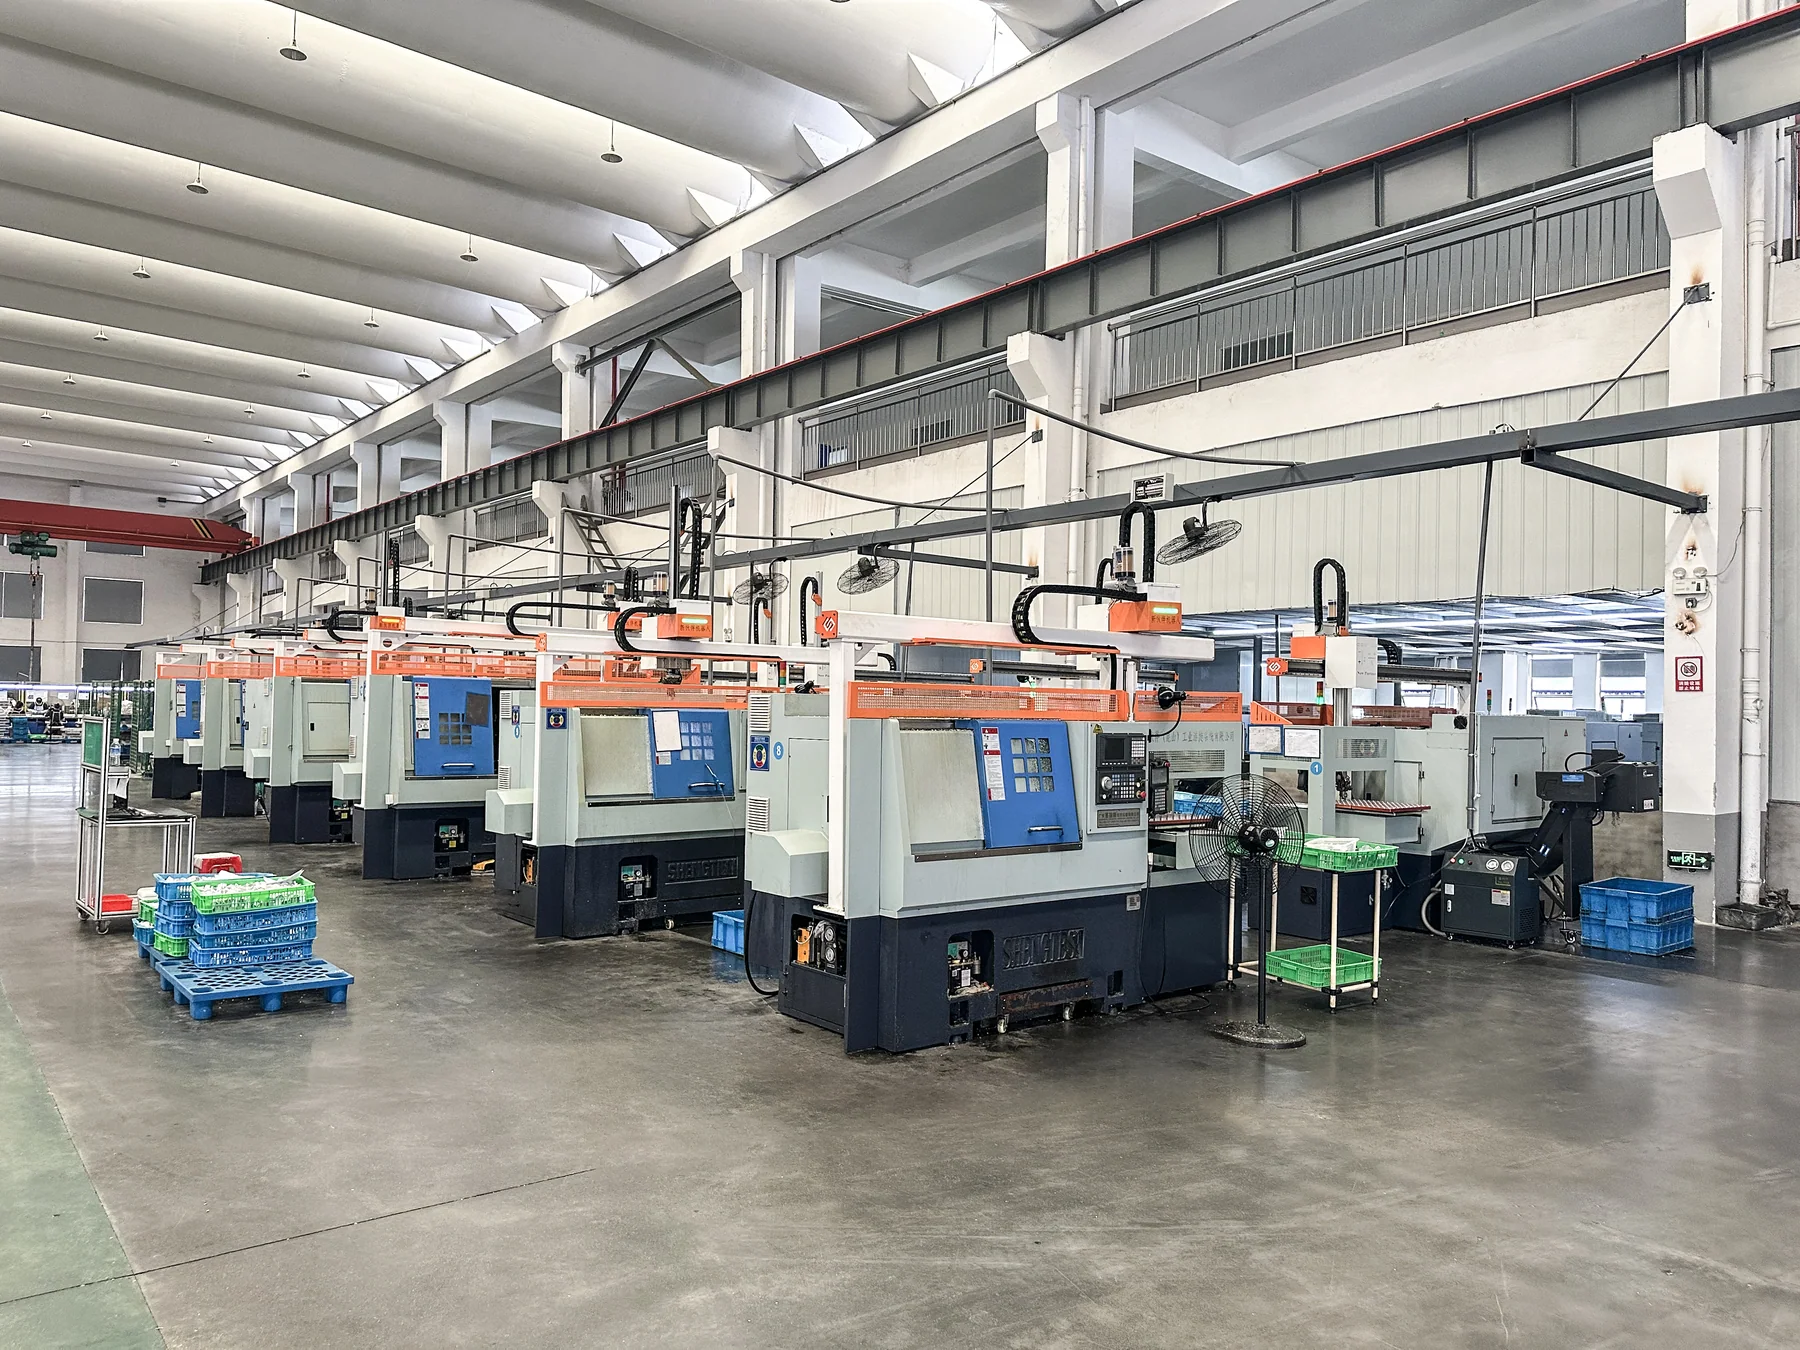
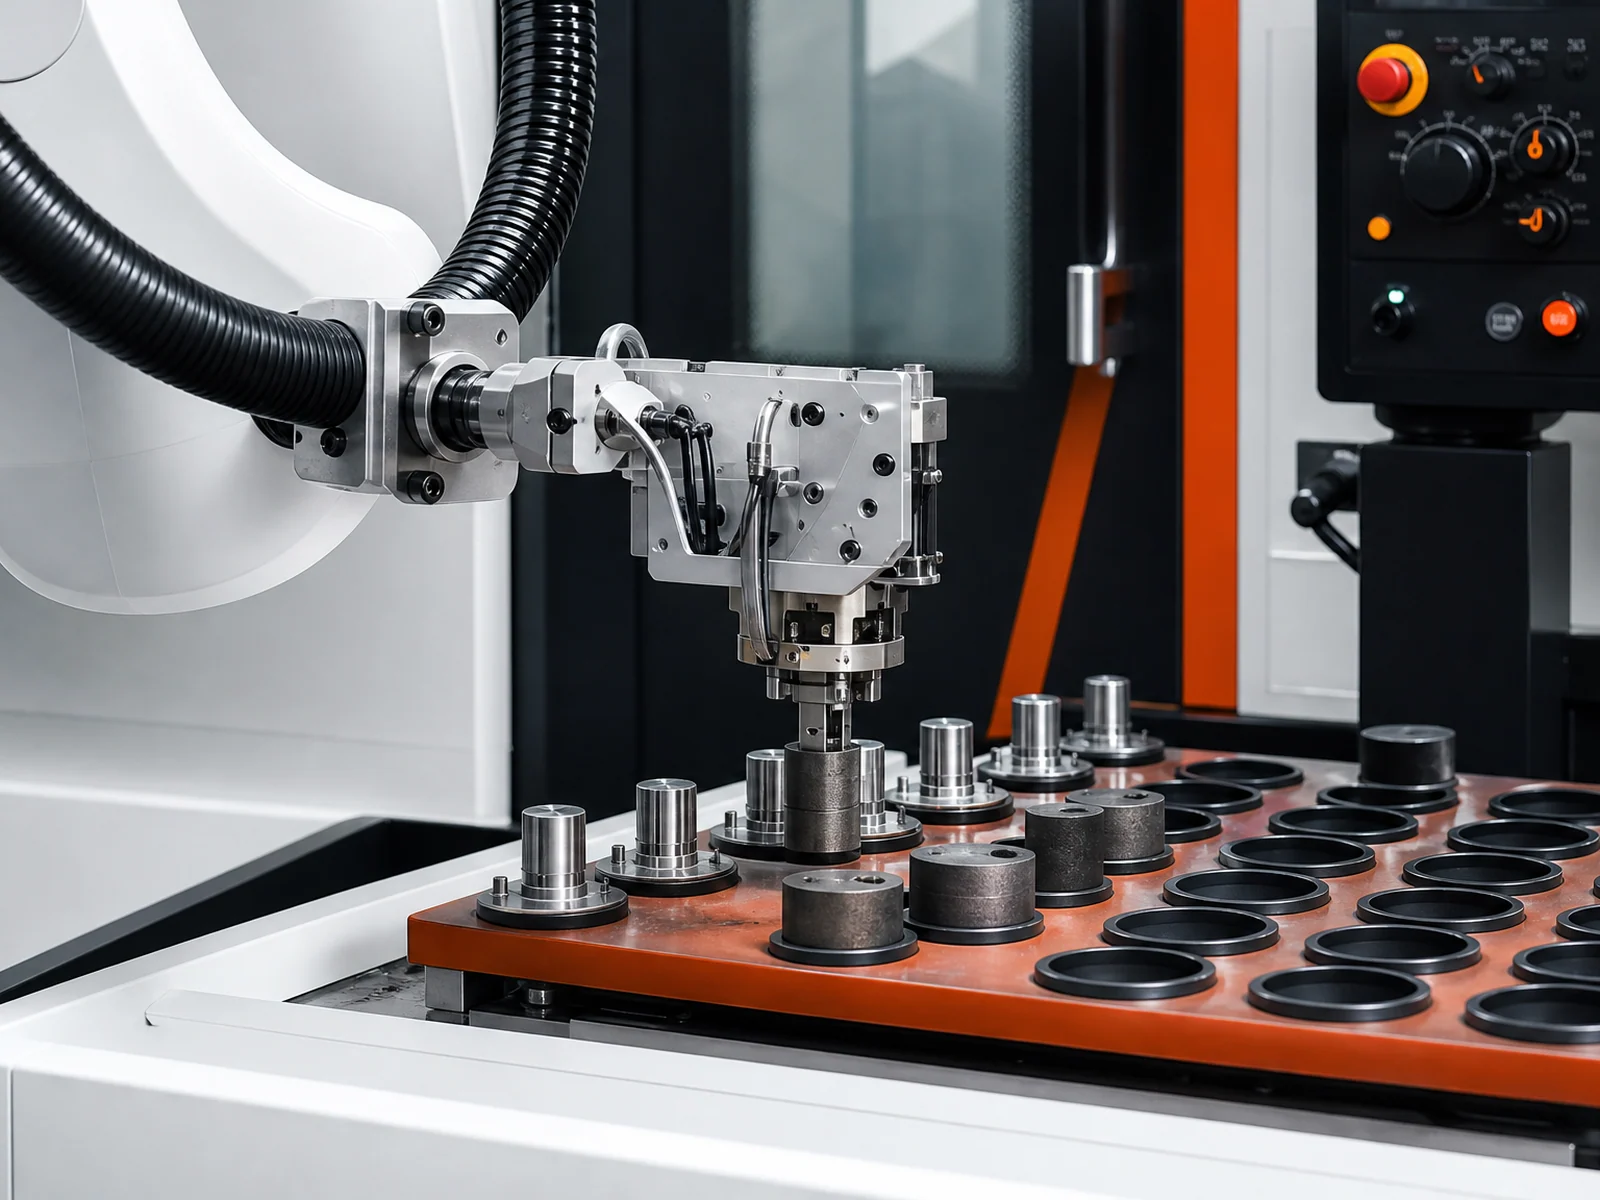
The two images below show comparable automation lines and equipment forms (including our own assembly workshop). They are not photographs of this project’s customer site; the actual configuration is subject to project assessment.
Source and verification status
Facts on this page are graded in the table below. No figure, customer name or acceptance conclusion appears without a stated origin.
| Source level | Material found | Used on this page |
|---|---|---|
| A — project records | None found (no equipment list, I/O list, commissioning or acceptance file) | — |
| B — project proposal | Case manuscript, case 04 (no separate solution document) | Sections 1–6, design requirements in 7, 10–11, 13, 14 |
| C — same workpiece / process | Site pages for liquid-cooling line fittings and stainless precision parts | Background on chuck clamping only |
| Business confirmation | Verbal confirmation, 21 Oct 2026 | Material class, machine makes, robot configuration, storage capacity, cycle time, project stage |
| D — other projects | Two reference photos from the site library | Form illustration only — not this project’s site |
Business-confirmed values come from a verbal confirmation on 21 October 2026. Machine models, machine count, material grades and dimensions are still to be confirmed from written records, and none of them has been estimated here.
Related pages
To discuss automation for a similar connector, send us the connector size range, material grade, lathe model and chuck type.
This page follows the same 19-block structure as the Chinese version. All facts and data-scope statements from the original proposal and case manuscript are retained. Items with no record remain marked “to be confirmed”; business-confirmed values are shown separately and were not mixed into the document-derived text.
Send the machine brand/model, part drawing or photo, blank and finished-part handling, single or multi-machine layout, target cycle and acceptance requirements.
Request an assessment Call +86 150 5020 2625