Starrag five-axis machining center loading and unloading
Starrag five-axis machining center loading and unloading: gantry robot or six-axis robot with automated storage and feeding, designed on the part and the cycle.
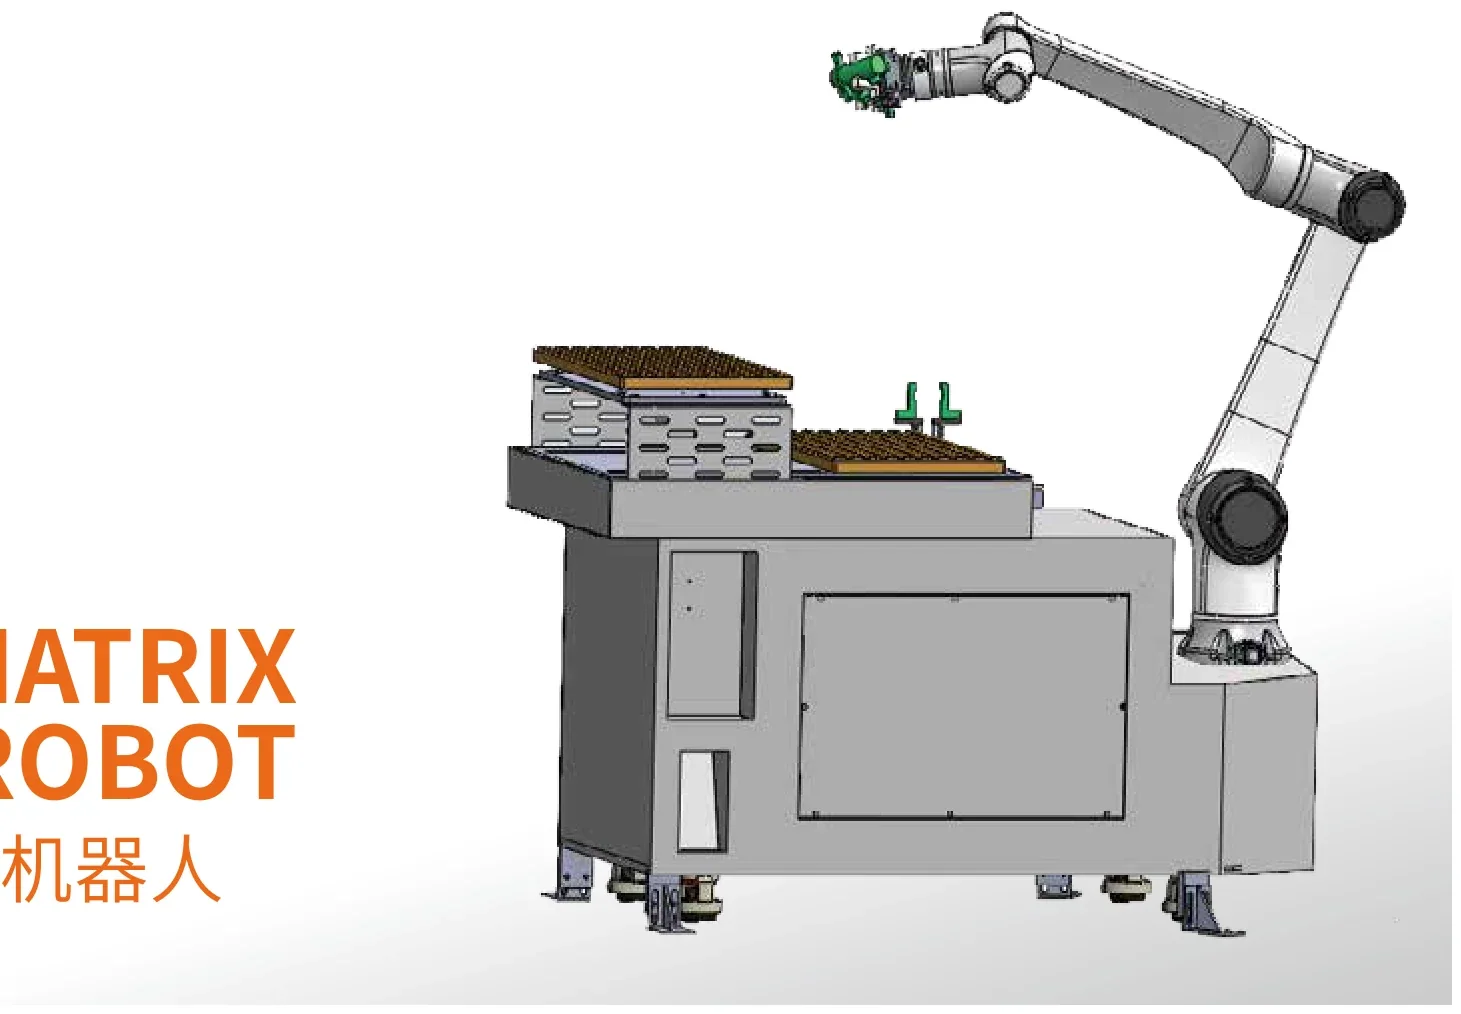
Starrag five-axis machining center loading and unloading solution
Starrag five-axis machining center loading and unloading: gantry robot or six-axis robot with automated storage and feeding, designed on the part and the cycle.
What Starrag five-axis machining center loading and unloading covers
This page covers one machine type: the five-axis machining center of Starrag, used where loading, clamping, unloading, part transfer and continuous production are still done by hand.
Starrag Group is based in Switzerland. Its main models include five-axis simultaneous machining centers.
Depending on the machine structure, the part size and weight, the cycle time, the fixture form, the production quantity and the shop layout, a cell can be built from a gantry robot, a six-axis robot, automated part storage, an automatic feeding mechanism, finished-part collection and an inspection unit, joining the manual handling motions into one continuous automatic cycle.
Where machining runs for long stretches, manual repetition has to come out and one operator has to cover several machines, the design has to answer seven questions at the same time:
- How the part is stored
- How the part is fed
- How the robot grips it
- How the machine clamps it
- How it is removed after machining
- How the finished part is collected
- How the next part comes in
Real five-axis machining center automation is therefore not one more robot on the floor: the machine, the feeding, the gripping, the fixture, the control and the safety interlocks form one production cell.
Why a Starrag five-axis machining center needs automated loading and unloading
In five-axis machining center work, manual loading and unloading usually consists of:
- Lift or pick the blank
- Align and locate it off-machine
- Zero-point or fixture pre-clamping
- Pallet into the machine
- Machining wait
- Pallet out
- Remove the finished part
- Record part data and traceability
When the cycle is stable, the part range is fairly uniform and the machine runs for long stretches, those repeated motions can be joined by an automation system. The machining characteristic here is long machining times and high part value, where consistency and traceability matter more than cycle time — which is exactly what makes the repeated motions worth fixing.
Taking Starrag as the example: Starrag builds five-axis simultaneous machining centers for high-value parts, where traceability alongside the handling is part of the requirement.
The system does not simply put a robot where an operator stood. It makes the following run in a fixed order:
- Feeding
- Picking
- Clamping
- Machining
- Unloading
- Collection
Add automated part storage and frequent manual replenishment turns into:
- Storage buffer
- Automatic feeding
- Robot picking
- CNC machining
- Finished-part collection
The concept for a Starrag five-axis machining center therefore has to be designed from the whole production cycle, not from a robot model number.
How a Starrag five-axis machining center loading and unloading system works
A typical automatic cycle can be designed as:
- Blank in
- Off-machine clamping and inspection station
- Part aligned and located
- Zero-point fixture pre-clamped
- Pallet buffer
- Robot or gantry picks the pallet
- Into the Starrag five-axis machining center pallet exchange position
- Pallet locked
- Machine confirms the lock and the part identity
- Swivel head and trunnion start simultaneous machining
- Machining complete
- Pallet out
- Finished part removed and data recorded
- Finished part collected or passed to inspection
Each of those motions needs its own state confirmation, for example:
- Is the part located on the pallet
- Is the pallet locked
- Is the fixture clamped
- Is the pallet exchange mechanism at the safe position
- Has the part identity been read
- Has the machining program finished
- Was the finished part removed and recorded
The robot works through the pallet exchange position, so the swivel head and the table motion envelope, the pallet size and the usable in-machine space have to be confirmed in the design, and the pick path is simulated before the concept is fixed.
The stability of an automatic system comes from the interlocks between those states, not from robot speed alone.
Loading and unloading methods for a Starrag five-axis machining center
01 Gantry robot loading and unloading
A gantry robot normally runs on a fixed path. It suits: machines that stay in position and stand in a row, a clear loading path, a fairly stable part range with continuous batches, a defined cycle, and one robot serving several machines. Typical structure: automated part storage → gantry robot → machine → finished-part collection.
02 Six-axis robot loading and unloading
A six-axis robot has a larger working envelope. It suits: handling motions that are complex or need the part flipped, several machines plus an inspection station, a wide part range with frequent changeover, and connecting deburring, washing or inspection. Typical flow: storage → robot → machine → robot → inspection or finished-part area.
03 Automated part storage and feeding
Automated part storage is the link that turns manual bar handling into buffering: blanks queue in the magazine and the robot takes them to the cycle, so replenishment becomes a scheduled batch job instead of a per-part one. It suits sites that want to lengthen the replenishment interval, a fairly uniform part range that can be supplied by tray or basket, night shifts or long unattended stretches, and several lathes sharing one feeding and collection route.
Choosing between them
| Handling unit | Matching feed method | Better suited to |
|---|---|---|
| Gantry robot | Storage magazine plus a fixed feed lane | Machines in rows, stable batches, a defined cycle |
| Six-axis robot | Storage magazine plus trays or baskets | Several part types, several stations, flipping and inspection |
| Gantry robot plus robot | Magazine feeding, robot unloads and sorts | A tight loading cycle where unloading needs separation and sorting |
The handling unit and the feeding method are two separate decisions: they can be chosen independently or combined.
Starrag five-axis machining center with automated part storage
Where the shop needs more than automatic handling — where frequent manual replenishment also has to come out — automated part storage is added in front of the machine and the system becomes:
- Storage magazine
- Automatic discharge
- Location
- Robot or gantry
- Starrag five-axis machining center
- Machining
- Finished-part collection
The storage magazine can take on:
- Blank storage
- Part buffering
- Automatic feeding
- Part location and selection
- Managing several batches
- Finished-part buffering
- Feeding several machines
One robot, two machines: Starrag five-axis machining center
When two Starrag five-axis machining centers have cycles, part sizes and a layout that suit shared feeding, the following can be designed:
- Storage magazine
- Gantry or robot
- five-axis machining center 1
- five-axis machining center 2
- Finished-part collection
That forms one multi-machine automation cell. A one-to-two configuration has to be calculated on:
- The cycle time of both machines
- The robot pick-and-place time
- The door opening time of both machines
- The part weight
- The robot payload
- The robot travel
- The distance between the two machines
- The storage capacity
- The scheduling logic when both machines finish at the same time
Not every pair of machines can share one robot. If the two cycles differ widely, or the machines stand too far apart, the robot path, the buffering method and the feeding structure have to be re-assessed.
Three machines and multi-machine lines: Starrag five-axis machining centers
Extended further, the cell becomes:
- Storage magazine
- Robot
- Machine 1
- Machine 2
- Machine 3
- Inspection
- Finished parts
On a multi-machine line the focus has already moved from loading and unloading to production task scheduling, part buffering, robot path and machine status management. The system has to decide:
- Which machine has finished
- Which machine is waiting for a load
- Which part should go into which machine
- Whether the magazine holds the matching part
- What the robot should do next
- Whether the other machines keep running after one alarms
A third machine is not simply added to the cell: the whole task scheduling and buffering logic has to be redesigned.
Which parts suit Starrag five-axis machining center automatic loading
Whether a part suits automated loading is decided by the part first. Across the typical work of a five-axis machining center, the common candidates are:
Impellers and blades
- Impellers
- Blades
- Blisks
- Flow guide parts
Complex surfaces
- Complex surface structural parts
- Aerospace structural parts
- Precision curved parts
Precision mould parts
- Precision mould cavities
- Mould inserts
- High surface quality parts
Industry parts
- Aerospace parts
- Energy equipment parts
- Medical device parts
- Precision machined parts
Whether a specific part suits automatic loading has to be confirmed on size, weight, shape, material, cycle time, clamping method, locating datum and the pose it arrives in. A name such as "shaft" or "disc" on its own is not a conclusion.
Part characteristics decide the automation method
This is one of the most important layers of the selection. On a five-axis machining center:
| Part condition | Design focus |
|---|---|
| Uniform size | Fixed fixture and fixed feeding |
| Small size | Precision location, purpose-made fixture, light-payload gripping |
| Heavy part | Robot payload and fixture load matched to the chuck size |
| Several sizes | Changeable fixture, configurable trays, recipe management |
| Fixed incoming orientation | Mechanical location |
| Random incoming orientation | Vision recognition / flexible feeding |
| Needs the other face machined | Robot flipping or a purpose-made flipping mechanism |
| Several operations | Transfer between operations by robot |
| Judgement needed after machining | Automatic inspection plus OK / NG sorting |
| Long continuous production | Automated part storage plus automatic feeding |
The concept therefore starts from the part, not from a robot model number.
How Starrag five-axis machining center loading solves clamping
In automated loading the machine fixture is a critical link. On a five-axis machining center the clamping form is a zero-point system and a pallet, and the system has to consider:
- Pallet and zero-point repeat location accuracy
- Fixture type
- Part locating and alignment datum
- Clamp confirmation
- Part-present detection
- Interference between the fixture, the swivel head and the trunnion
- Space to remove the finished part
- Effect of difficult-to-cut material chips and coolant on the locating face
Typical working cycle:
- Pick the part off-machine
- Align and locate it
- Zero-point pre-clamping
- Pallet into the machine
- Pallet locked and confirmed
- Swivel head and trunnion machine
- Pallet out
- Finished part removed and recorded
The machine only moves to the next state after the clamped condition is confirmed. These are often difficult-to-cut materials, so chip form and the coolant method affect how clean the locating face stays. Automated loading is therefore not simply "pick it up and put it in".
Automatic inspection after machining
Where the project needs an in-process quality decision, an inspection unit can be added after the five-axis machining center, configured to the requirement:
- Present / absent
- Dimensions and geometric tolerance
- Appearance
- Curved surface profile
- Orientation
- Defect
- Character recognition
- Barcode and part identity
Forming:
- Starrag five-axis machining center
- Automatic unloading
- Vision or dimensional inspection
- OK to the finished-parts area
- NG to the reject area
The line then runs from automatic machining to automatic machining plus automatic judgement plus automatic sorting. On this site the corresponding line is 08 Vision Inspection Systems.
When a gantry fits, and when a robot fits
Neither option is automatically better; the shop decides.
| Item | Gantry robot | Six-axis robot |
|---|---|---|
| Multi-machine line | Suits a fixed layout | Suits complex layouts |
| Spatial motion | Linear axes; in-machine handling is limited by the structure | Multi-joint, can work around the head and the trunnion |
| Flipping and pre-clamping | Off-machine clamping is the norm | More flexible, can flip and pre-clamp off-machine |
| Data traceability | Needs an added identity-reading step | Easier, can join the same cell |
| Layout change | Beam and travel have to be redesigned | Comparatively flexible |
| Typical case | Small and medium parts in stable batches | High-value complex parts, mixed-part cells |
The final choice also depends on the swivel head and trunnion motion envelope, the part weight, the pallet size, the cycle, the traceability requirement and the safety area.
What a Starrag five-axis machining center project needs to be quoted
For an automation retrofit, prepare the following before the first review:
Part
- Part name
- Part photo
- Length
- Diameter
- Height
- Weight
- Material
- Incoming condition
Machining
- Cycle time
- Machining program
- Machining time per part
- Daily output
- Monthly output
- Number of operations
Machine
- Starrag model
- Number of machines
- Swivel head and trunnion size and motion range
- Pallet or zero-point specification
- Machine door width and usable in-machine space
- Table load capacity
- Machine layout
Automation
- Gantry or robot
- Automated part storage
- Flipping
- Vision
- Inspection
- Multi-machine line
- MES
Site
- Plant size
- Machine positions
- Safety area
- Loading and unloading space
- Walkways
The more complete these documents are, the closer the concept is to the real job.
Starrag five-axis machining center loading: implementation focus
A project lands on the shop floor when these are verified:
01 Part location
Whether the part reaches the pick-up position reliably.
02 Fixture
Whether the robot gripper holds parts in different states reliably.
03 Machine interface
Whether the robot and the machine exchange run states reliably.
04 Cycle time
Whether the robot cycle matches the machine cycle.
05 Exception handling
How the system pauses, resets and recovers from a failed pick, a machine alarm or a part that is not in position.
06 Safety
Safety door, light curtain, safety area, emergency stop, robot safety and the human-robot boundary.
07 Manual takeover
Whether an operator can step in quickly when the automation trips.
A stable automatic system is not only one that completes its motions in normal running: it is one that recovers safely and in a controlled way from an abnormal state.
Which business lines this page connects to
A Starrag five-axis machining center loading page does not stand alone; it sits inside the wider automation system. The lines below are upstream or parallel to it.
Together they form the complete chain:
- Storage magazine
- Gantry or robot
- Starrag five-axis machining center
- Automatic inspection
- MES
Starrag five-axis machining center loading and unloading: common questions
Can Starrag five-axis machining centers be loaded and unloaded automatically?
Yes. Five-axis machines should use off-machine clamping plus pallet exchange first, to avoid interference between in-machine handling and the swivel head or trunnion. The pick path is simulated during the concept stage.
Why a pallet rather than in-machine pick and place on a five-axis machine?
The in-machine space is taken by the swivel head and the trunnion, so in-machine handling both consumes machining time and risks interference. Clamping off-machine and exchanging the whole pallet keeps downtime shortest.
Is automation worth it for small batches?
Where parts are valuable, manual work is error-prone or process traceability is required, it can be justified even in small batches: the gain is consistency, yield and traceable data rather than cycle time.
How is a one-to-two Starrag five-axis cell designed?
It has to be calculated on the pallet exchange cycle of both machines, the robot travel and the number of pallets, and the scheduling logic for part changeover and program calls has to be confirmed.
How far should traceability go?
At least part-level identification, the loading and unloading times and the machining program record, bound to the pallet number so a batch can be queried later.
What do you need for a Starrag five-axis loading project?
The machine model and the swivel head and trunnion specification, the part drawing with size and weight, existing fixture or zero-point information, the cycle time, the traceability requirement and the shop layout.
Project case information
Machine brand
as in the page title
Machine model
to be filled from the project record
Automation form
gantry robot / six-axis robot — from the project record
Part
to be filled from the project record
Part size / weight
measured data
Number of machines
measured data
Storage method
measured data
Cycle time
measured data
Inspection method
measured data
Project site
project material
These fields are kept as placeholders in the company's own format: nothing that has not been confirmed by project documents is written on the page. This page describes how loading and unloading is engineered for this machine family and brand line — it is not a claim that a project has been delivered on this machine. If you run machines of this brand, contact us to add real project information.
Note The brand and model information on this page comes from the company's own material and is used to explain the differences in automation fit between machine families, series and models. A brand name does not mean agency, authorization, certification or partnership, and does not mean that a project has been completed on a machine of that brand. Whether a specific model can be loaded and unloaded automatically has to be confirmed on site against the chuck, the door and guard structure, the fixture type and the layout.
Where to continue
Send the machine brand/model, part drawing or photo, blank and finished-part handling, single or multi-machine layout, target cycle and acceptance requirements.
Request an assessment Call +86 150 5020 2625