Vision Inspection Systems | In-Line CNC Part Inspection
Automatic in-line inspection after machining: dimensions, hole diameter and position, appearance, presence and assembly completeness, with OK / NG sorting.
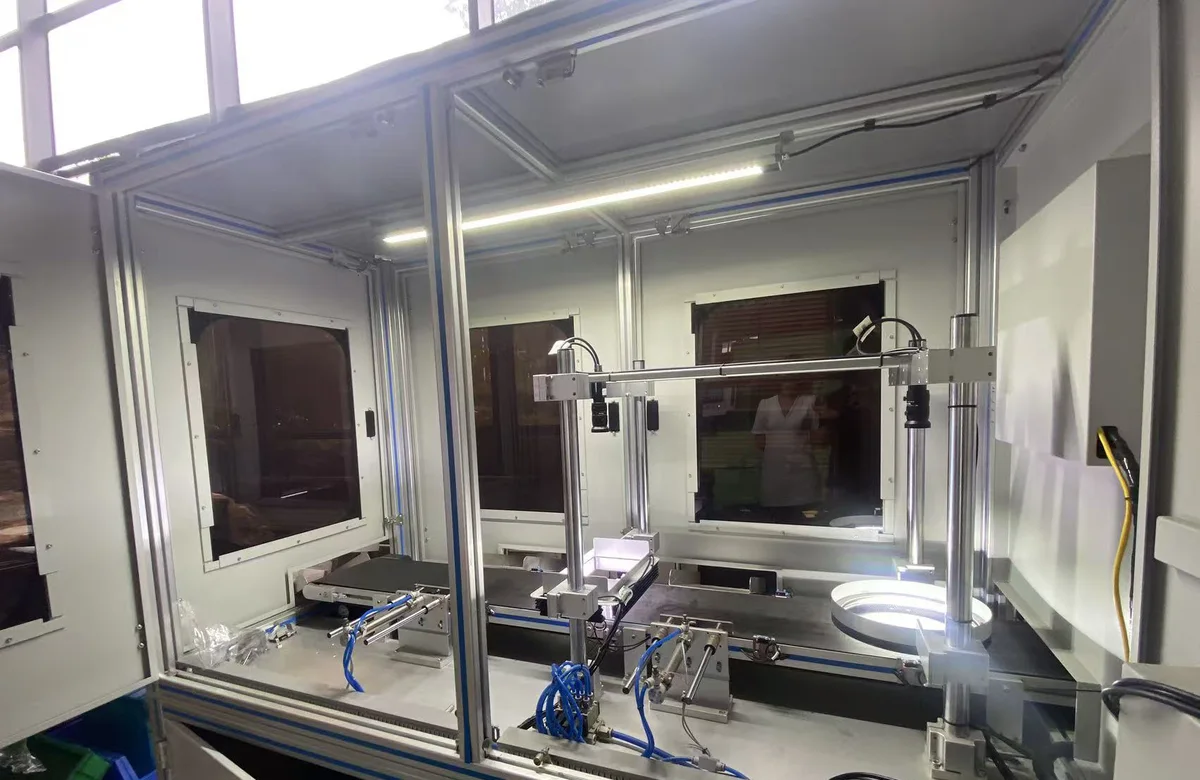
Vision Inspection Systems
Inspection built into the loading flow: the part is measured as it comes off the machine, so rejects never reach the next operation. Automatic judgement of dimensions, appearance, hole diameter and hole position, presence and assembly completeness, with OK / NG sorting and data records.
Vision inspection, in short
It uses industrial cameras, optics, lighting and vision algorithms to capture and judge the appearance, dimensions, hole positions, characters and defects of a part, and to output a result. The point is not to photograph the part but to turn the judgement into an action — sorting, release or isolation — and to record it. It removes sampling and rework after the fact and puts the decision inside the production flow. It fits machined parts with clear pass and fail criteria, where good and bad parts can be distinguished in an image and samples can be tested.
After machining, how is a part judged automatically?
Where inspection sits in the flow.
After machining, how is the part judged automatically? The part comes off the machine, the handling unit places it at an inspection station, the optics capture it, the algorithm judges it, and the result drives what happens next: released as OK, isolated as NG, or routed to a re-check.
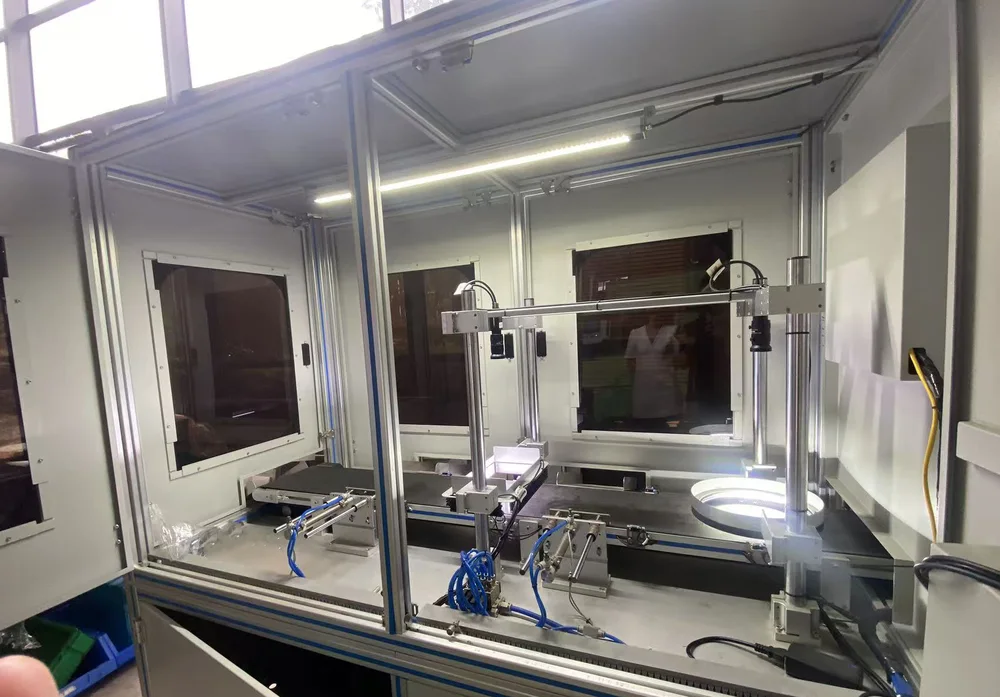
What vision inspection is
Take it out of the "fit a camera" frame first.
Vision inspection captures and judges the appearance, dimensions, hole positions, characters and defects of a part with industrial cameras, optics, lighting and vision algorithms, and outputs a result.
The point is not capturing an image. It is that the judgement drives sorting, release or isolation and can be recorded.
Two things have to be agreed before anything else: what exactly is being judged, and what separates a pass from a fail.
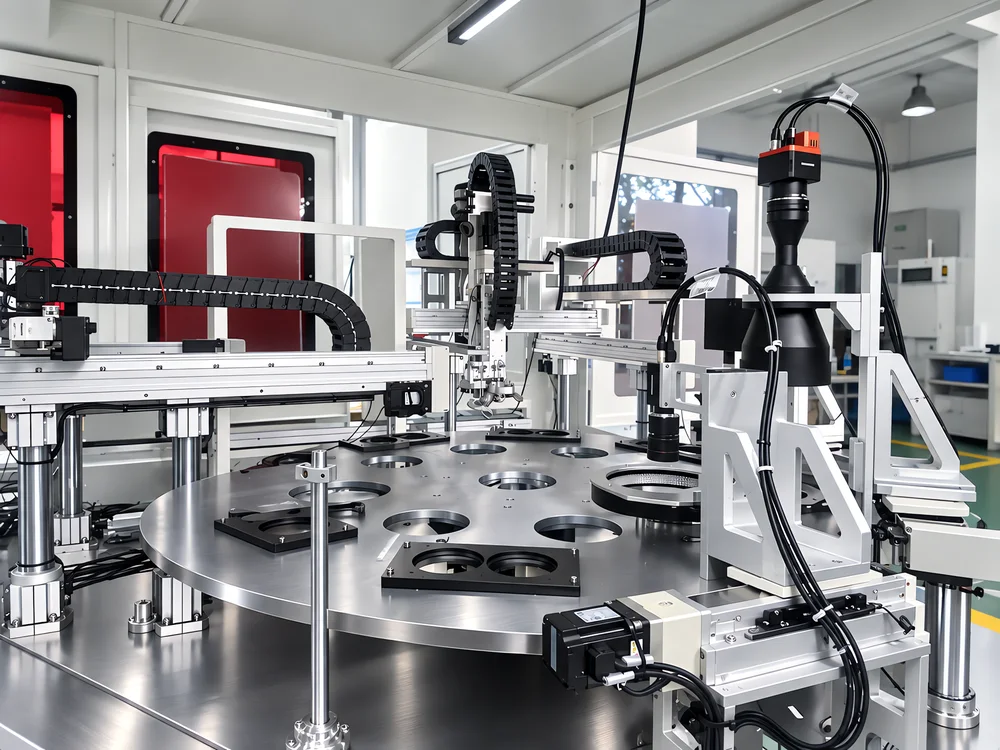
Why automatic inspection is needed
Not because a machine is better than a person, but because some judgements suit a system whose criteria never change.
The decision is made on the part that is actually being produced.
The same criteria are applied to every part in every shift.
Rejects are taken out before they reach the next operation.
The result and the time can be traced back afterwards.
Repetitive dimensional and appearance checks are the cases where a system is strongest.
Not "a machine beats a person", but some judgements are better handed to a system whose criteria never change.
What vision inspection can inspect
The items that can be assessed, by class, with the boundary of each class.
| Category | Typical items | Note |
|---|---|---|
| Presence and assembly completeness | Part present, screw present, seal present, pin present, connector present | The most established class of vision inspection |
| Dimensions and geometry | Length, width, outside diameter, center distance, spacing, angle | Needs a stable locating datum and an optics scheme derived from the tolerance |
| Holes and hole position | Hole present, number of holes, hole position, hole diameter | Three different levels of difficulty: presence, position, diameter |
| Appearance and surface defects | Scratches, burrs, marks, discoloration, damage | Depends on the material, surface and lighting |
| Characters and codes | OCR, character presence, barcode and QR code reading | Reading the content and judging the quality are different tasks |
| Color difference | Color and shade | Needs a dedicated scheme |
Inspection classes and typical items. Specifications as stated in the product brochure; final configuration depends on the application.
Which items can be done, and to what level, is assessed from the material, the surface, the tolerance and the defect characteristics.
Which dimensions can vision inspect?
Dimensions are the class that most depends on stability.
What affects the result
Dimensions are the class of vision inspection that most depends on stability: the optics scheme is derived backwards from the tolerance, and repeatability is confirmed on sample parts.
Can vision inspect hole diameter and hole position?
First separate "is there a hole" from "is the diameter acceptable".
A presence judgement; the easier end.
A relative position judgement; needs a clear locating datum.
A fine measurement; needs telecentric optics where necessary, dedicated lighting, stable locating and possibly a laser or displacement sensor.
What a diameter measurement needs
Hole diameter and hole presence are not the same level of difficulty. The three levels are assessed separately.
What appearance defects can vision cover
Appearance depends on lighting and surface condition more than dimensions do.
What decides the result
Appearance inspection depends more on lighting and surface condition than dimensional inspection does, so two projects with the same words can need completely different schemes. The conclusion follows tests on real samples.
Can vision inspect scratches?
It can be assessed, but the conclusion can only come from sample tests.
What the test needs
No unverified detection limit is quoted. Whether a scratch can be seen depends on its contrast against the background, the resolution of the optics, the lighting and the surface state — so the answer comes from tests on real defects.
Can vision inspect burrs?
Part of the visible burrs can be assessed, but which kind of burr has to be clear.
The difficult cases
Part of the visible burrs can be assessed. The hard cases may need multi-angle vision, 3D vision, laser or other sensors, or a mechanical check, and the scheme has to be tested.
Inspecting whether an assembly is complete
Presence and assembly completeness is the most established class, and the one whose value is most often underestimated.
Presence and assembly completeness is the most established class of vision inspection and the one whose value is most often underestimated. It is judged position by position — this feature should be here, or should not — and is well suited to tests on real assemblies.
Characters, OCR, barcodes and QR codes
Reading and judging quality are not the same concept.
What do the characters or the code say?
Does the character or code meet the requirement? A printed but readable character may still be a reject, depending on the customer's criteria, and that has to be agreed at proposal stage.
Reading and judging are two different tasks. Which one is required has to be stated before the scheme is designed.
What is the difference between 2D and 3D vision inspection?
Two imaging methods, two different routes.
What 2D handles
What 3D adds
| Item | 2D | 3D |
|---|---|---|
| Information | Plane image | Height, depth and three-dimensional form |
| Typical items | Plane dimensions, outline, characters, surface defects, presence | Height, spatial position, three-dimensional defects |
| Choice basis | Object, tolerance, surface, speed, cost and installation space | Same |
2D and 3D vision compared. Specifications as stated in the product brochure; final configuration depends on the application.
Neither is always better; the object, the accuracy, the surface, the speed, the cost and the installation space are decided together.
In-line inspection and off-line inspection
This is not a question of technical level but of production flow.
In-line
Off-line
This is not a question of technical level but of production flow. Where the line cannot be changed yet, an independent off-line station is a reasonable first step.
What an automatic inspection system is made of
The camera is one part of it; stable inspection comes from the whole system.
| Part | Role |
|---|---|
| Part locating | So the part stops in the same position and pose every time. |
| Fixture | Holds the part without blocking the inspection area. |
| Industrial camera | Captures the image; chosen from the feature and the accuracy required. |
| Lens | Decides the field of view, the working distance and the image quality. |
| Lighting | Decides the contrast between the feature and the background. |
| Vision controller / industrial PC | Runs the algorithms, manages the flow and stores results. |
| Vision algorithm | Locating, measurement, defect analysis, OCR, code parsing. |
| PLC | Motion timing, signal exchange with machine and robot, OK / NG output. |
| Sensors | In-position checks, safety interlocks, supporting judgements. |
| Robot or mechanism (on request) | Fitted when picking, flipping or sorting is needed. |
| Conveyor (on request) | Fitted when parts have to flow or be diverted. |
| OK / NG sorting mechanism | Turns the judgement into a physical action. |
| Safety system | Guarded doors, light curtain and emergency stop for the site requirements. |
| MES / data interface (on request) | Connected to the production system where the project requires it. |
Inspection system parts and their role. Specifications as stated in the product brochure; final configuration depends on the application.
The camera is one part of it. Stable inspection comes from the whole system.
Why vision inspection is not only about the camera
The same part under a different light can image completely differently.
What lighting decides
The same part can image completely differently under different lighting. Reflection on bright metal can both hide a defect and create one that is not there, which is why lighting is designed together with the object.
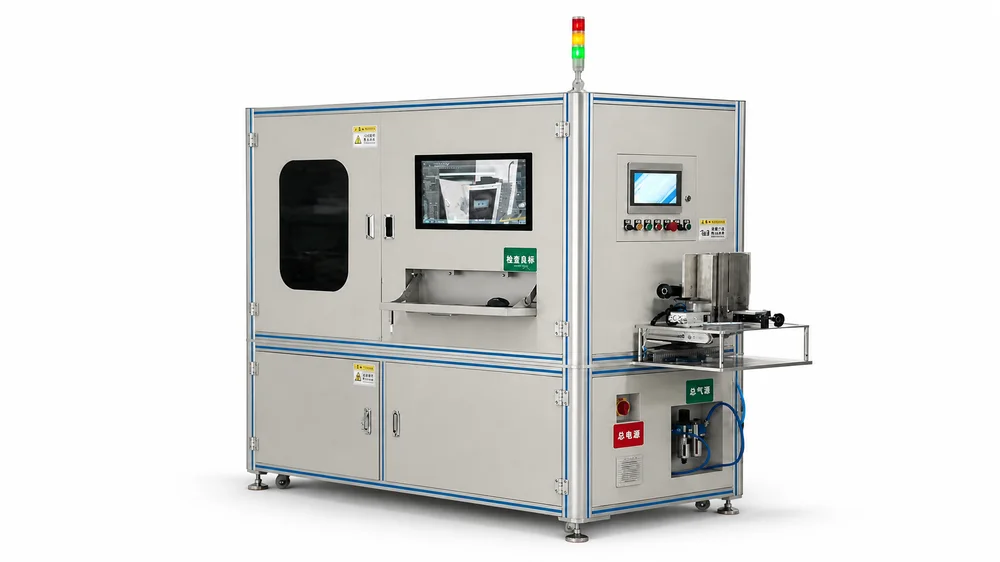
How vision inspection accuracy is determined
Accuracy is not a number that can be quoted on its own.
What affects the final result
Accuracy is not a number that can be quoted on its own. It is derived from the requirement: the product requirement and the inspection tolerance come first, then the method, the optics and the algorithm, and finally the result is verified on real samples. The same system performs differently on different features and different tolerance bands, so no fixed accuracy figure is written here.
How long does one vision inspection take?
See what the cycle is made of before talking about speed.
Inspection cycle = inspection + handling + data processing + sortingThe final cycle is fixed by the project test.
More inspection items, more cameras and more complex algorithms all make the cycle longer. The final cycle is fixed by the project test; no figure is promised here.
Automatic OK / NG judgement
One of the clearest differences from vision-guided feeding.
What happens to an OK part
What happens to an NG part
This is one of the clearest differences from vision-guided feeding: feeding vision decides which part to pick, inspection vision decides whether a part passes — and the result drives what happens to the part.
What happens after a part is judged NG
An inspection system cannot output only "NG".
An inspection system cannot output only "NG". Where a reject goes, and what happens to it, has to be settled together with the customer's production flow at proposal stage. The list above is the common set of destinations.
How inspection data is recorded and traced
Whether the data can be used matters more than whether it exists.
| Aspect | Answer |
|---|---|
| What is recorded | The fields listed above, within the actual system capability |
| How it is stored | In the vision controller or host system's database |
| Interface | MES or production system designed to the project requirement |
| Traceability | Queried back by part ID or batch |
How the data is recorded. Specifications as stated in the product brochure; final configuration depends on the application.
Whether the data can be used matters more than whether it exists. Where a project has no real MES interface, this page does not describe the data loop as complete.
Vision inspection with a CNC lathe
After turning, the part is judged at the unload position so the problem does not leave the operation.
Turning complete.
The arm takes the part out.
Dimensional or appearance inspection at the station.
A result for the part.
Routed by the result.
Inspection items are determined by the real part or the project requirement; this page does not preset them. Turned parts are most often linked to outside diameter, length and appearance.
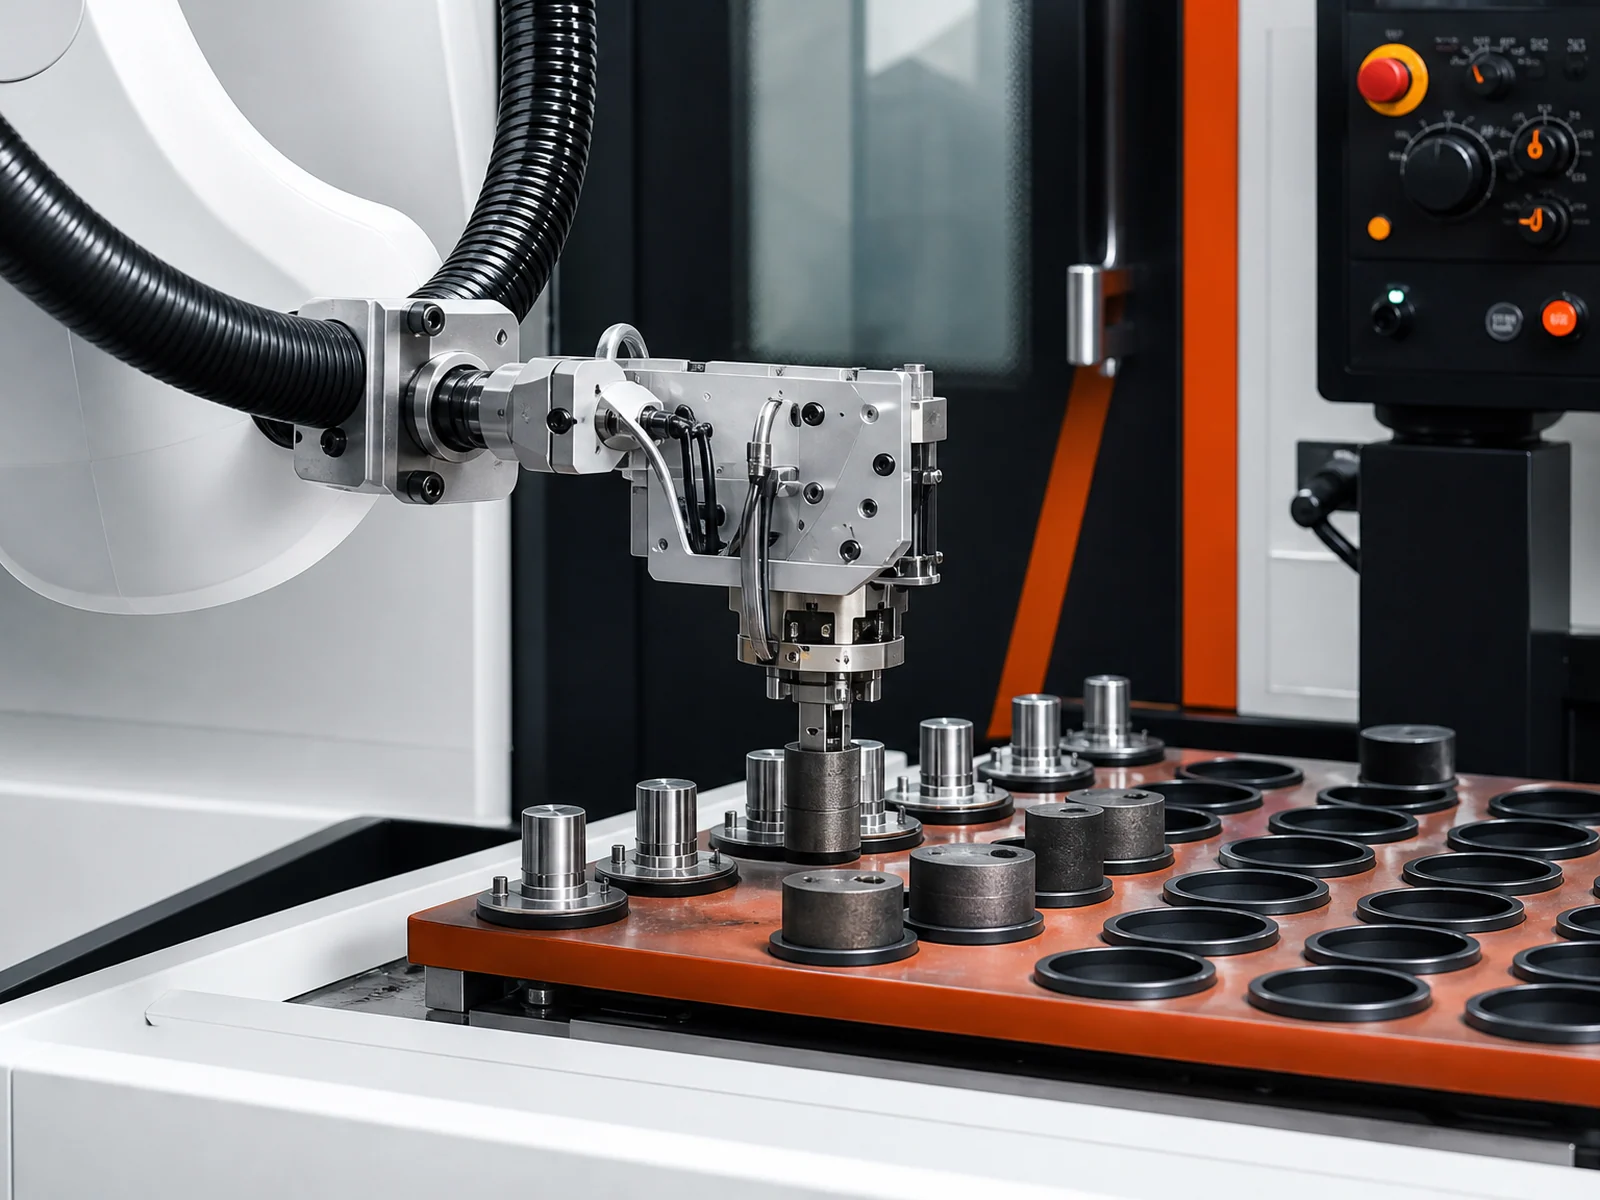
Vision inspection with a CNC machining center
Hole position, contour and orientation checks after milling and drilling.
Milling, drilling and tapping complete.
The robot takes the part to the inspection station.
Performed to the project requirement.
Result.
OK continues, NG is isolated.
The most common quality dispute on machining center parts is hole position and contour; those items are confirmed together with the locating and optics scheme during the test.
Vision inspection with automated storage
Storage handles supply and buffering; inspection handles the quality decision — two different jobs, written separately.
Blanks or semi-finished parts buffered and supplied.
Machining.
Inspection after machining.
Result.
OK to the finished magazine, NG isolated.
Magazine positions, capacity and refill method belong to the storage line; this page covers inspection and the quality decision only.
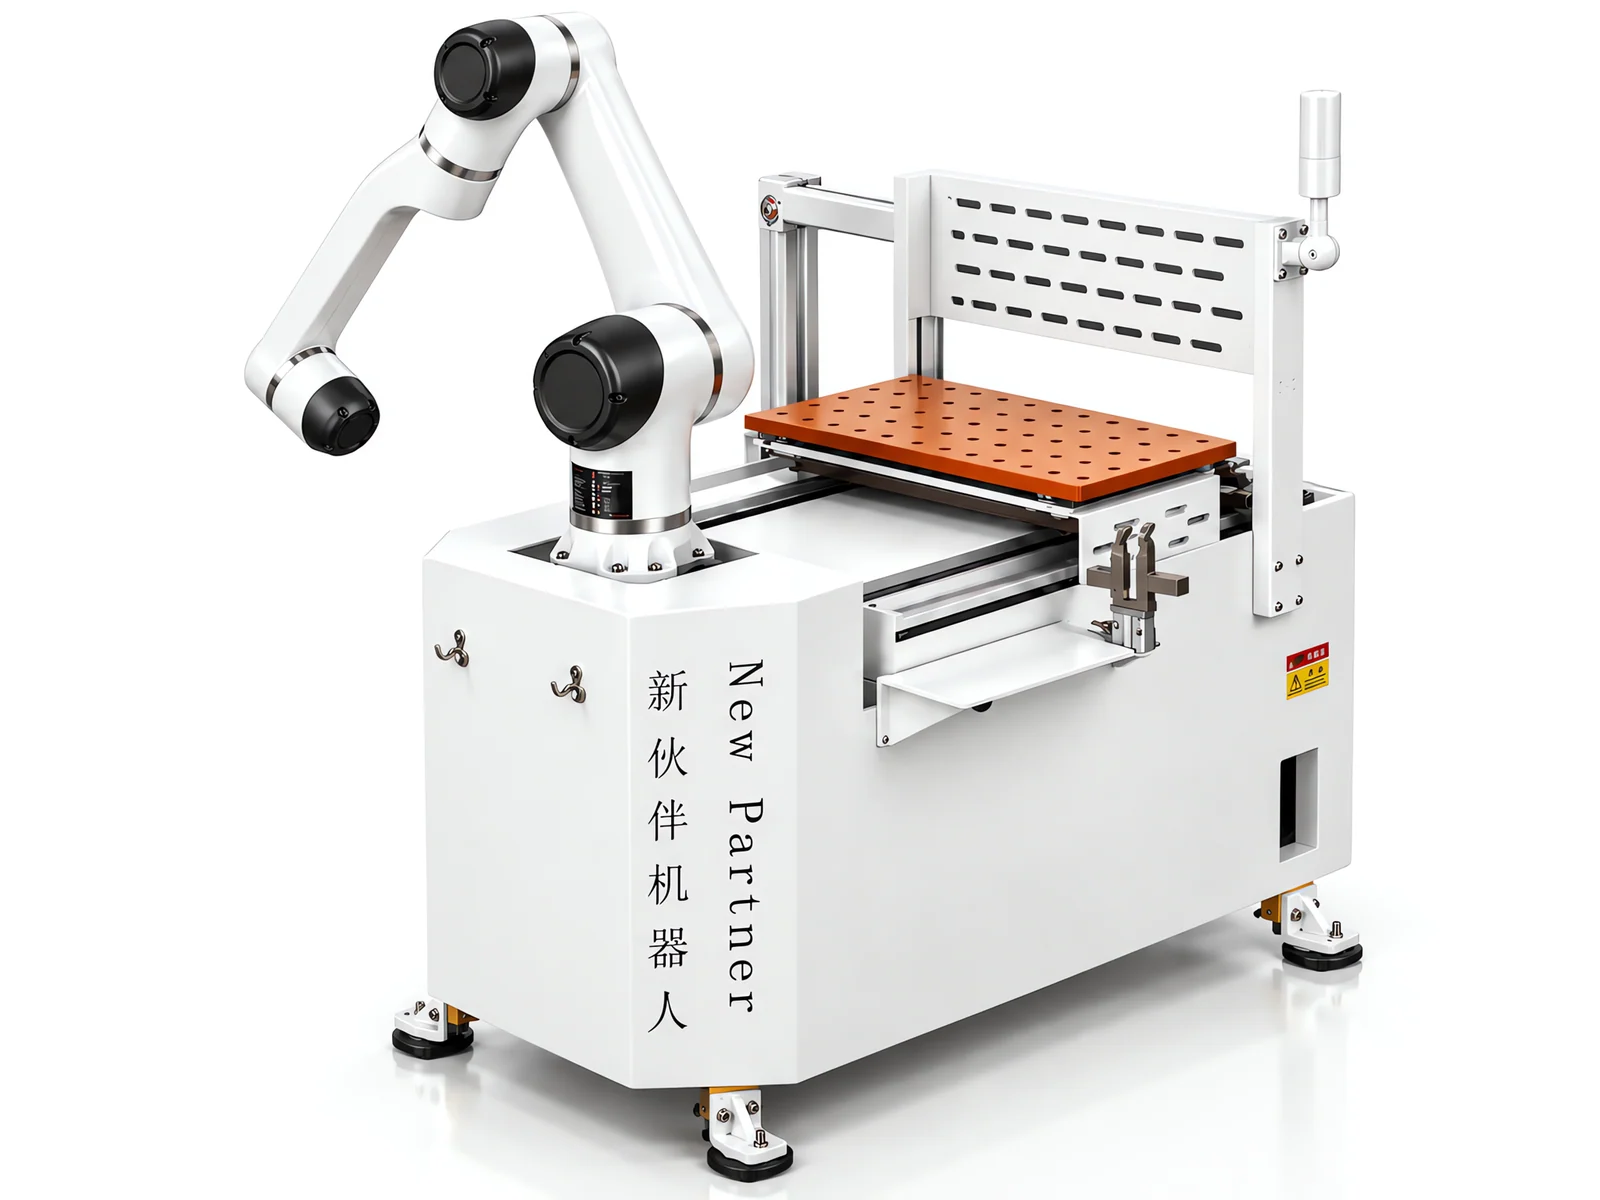
Vision inspection with a robot
The robot picks, carries, flips, places and sorts; vision inspects, judges and outputs the result.
From the machine or the feeding position.
To the inspection pose, flipping where needed.
Image capture and judgement.
OK / NG and data to the executing side.
Parts placed by result.
Robot plus vision inspection plus OK / NG sorting is a common combination, but the robot does not judge quality: the judgement comes from the optics and the algorithm.
Vision inspection with flexible feeding
One complete chain: loose parts in, good parts out. Both ends use vision, but they solve two different things.
Parts arrive loose in a bin.
Which part to pick and in what pose.
Picks and loads by the recognition result.
Machining.
Judged after machining.
Routing.
The vision on this page answers whether the part meets the requirement after machining; recognizing and picking loose parts belongs to vision-guided flexible feeding, and the two pages do not repeat each other.
Vision inspection with MES and production data
The inspection result has to enter the management flow for traceability to mean anything.
Performed to the inspection items.
Result.
Result, values, NG reason and images.
Connected where the project requires it.
Queried by batch or part ID.
It can only be written as "implemented" where the real system supports it; otherwise it is described as MES integration designed to the project requirement.
Which inspection method suits which quality requirement
The correct order in engineering selection: use the simplest method that works, and only go up a level when it does not.
| Requirement | Preferred method |
|---|---|
| Presence of a single feature | Sensor where a sensor can do it reliably, otherwise vision |
| Presence of several features or assembly completeness | Vision, judged position by position |
| Plane dimensions within a normal tolerance | 2D vision with a stable locating datum |
| Hole position | 2D vision with a clear datum |
| Hole diameter to a tight tolerance | Telecentric optics, or a dedicated measuring device |
| Appearance and surface defects | 2D or 3D vision depending on the defect and the surface |
| Height and three-dimensional form | 3D vision where the scheme supports it |
| A dimension that must be touched to be determined | Contact measuring equipment |
| Internal structure | Other methods entirely |
Requirements and the preferred method. Specifications as stated in the product brochure; final configuration depends on the application.
The correct order in engineering selection is to use the simplest method that works, and only go up a level when it does not. This table is there to rule options out, not to rank them.
Typical solutions
Ten common combinations, to show how this kind of requirement is usually put together.
In-line inspection cell on a machining line
- System
- Handling unit, inspection station, judgement, OK / NG routing
Off-line inspection station
- System
- Manual or robot loading, inspection, judgement, records
Station with rotary table
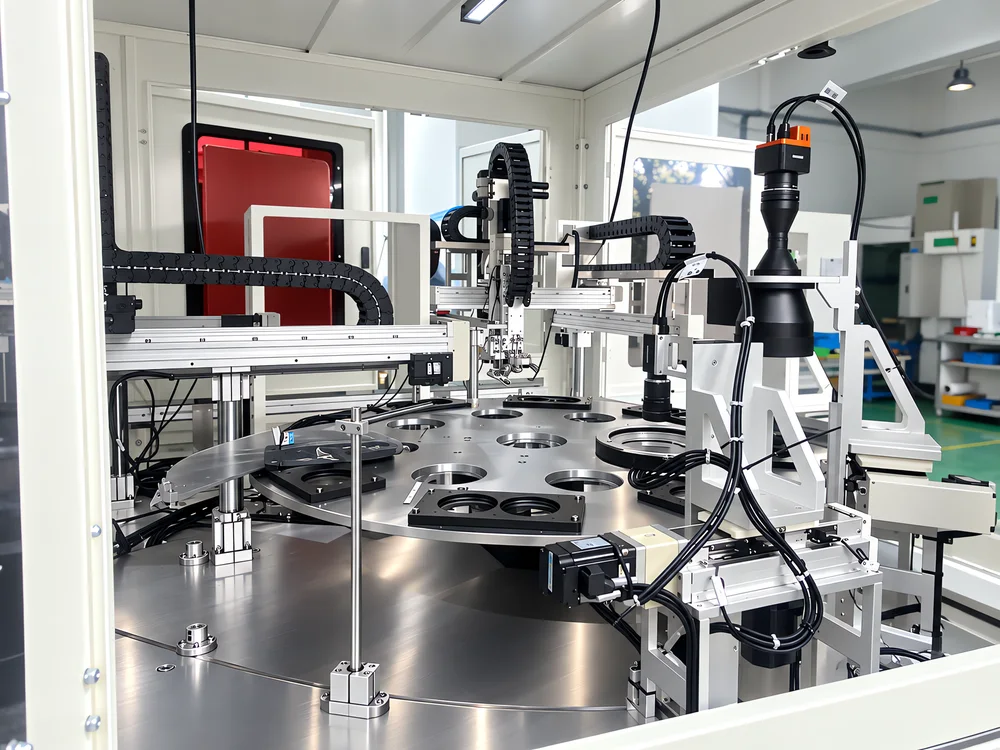
- System
- Rotary indexing between load, inspect and sort positions
Inspection with robot sorting
- System
- Robot picks, presents, inspects and sorts by result
Dimensional inspection station
- System
- Stable locating, telecentric optics where needed, dimensional algorithm
Appearance inspection station
- System
- Dedicated lighting, surface defect algorithm
Hole and hole position inspection
- System
- Locating datum, optics and hole measurement algorithm
Character and code station
- System
- OCR or code reading with quality judgement
Inspection with data interface
- System
- Results recorded and exchanged with the production system
Inspection combined with feeding
- System
- Vision feeding at the front and inspection after machining, two different jobs
Ten common combinations, to show how this kind of requirement is usually put together.
How inspection lands in each industry
No industry is described by its name alone: every one lands on the part, the process, the quality problem and the inspection item.
Medical & Implant Parts
Tight dimensional and surface requirements.
General machining
Mixed dimensional, appearance and presence checks.
No industry is described by its name alone: every industry lands on the part, the process, the quality problem and the inspection item.
Which parts suit vision inspection?
Organized by part characteristics rather than industry names.
Turned parts
Outside diameter, length, appearance, burrs
Often judged at the unload position
Milled and drilled parts
Hole position, hole diameter, contour, orientation
Hole position and contour are the usual disputes
Small precision parts
Dimensions, appearance, presence, sorting
High inspection frequency; sorting follows the result
Parts with printed marks
Characters, codes, print quality
Reading and quality judgement are separate tasks
Assemblies
Presence, orientation, completeness, wrong assembly
Suits tests on real assemblies
Parts with tight tolerances
Dimensions and surface to a tight tolerance
Optics scheme derived from the tolerance
Organized by part characteristics rather than by industry name. Which items can be inspected is confirmed on samples.
What to send for an inspection assessment
The more complete this list, the closer the scheme comes to something that can be built.
Part information
Inspection requirement
Samples
Production and system
The more complete this list, the closer the scheme comes to something that can be built.
Manual, sensor, 2D, 3D and dedicated measuring compared
This table is there to rule out schemes that do not fit, not to rank them.
| Dimension | Manual | Sensor | 2D vision | 3D vision | Dedicated measuring |
|---|---|---|---|---|---|
| Judgement criteria | Experience-dependent | A fixed threshold | Fixed criteria | Fixed criteria | Fixed criteria |
| Repeatability | Varies | High for one state | High within the scheme | High within the scheme | High |
| Full inspection | Hard | Possible | Possible | Possible | Slow |
| Appearance defects | Possible | No | Possible for surface defects | Possible including three-dimensional | No |
| Internal features | No | No | No | No | Some |
| Records | Manual | Signal only | Results recorded | Results recorded | Results recorded |
| Changeover | Fastest | Adjust the sensor | Recipe change | Recipe change | Slowest |
| Cost and effort | Lowest | Low | Medium | Higher | Highest |
Inspection methods compared. Specifications as stated in the product brochure; final configuration depends on the application.
The table is there to rule out schemes that do not fit, not to rank them.
Why vision inspection must be verified on samples
Inspection capability is not designed, it is verified.
| Difference | Effect on the scheme |
|---|---|
| Difference | Effect on the scheme |
| Defect contrast against the background | Whether the defect can be captured, and with which optics |
| Surface reflection | Lighting scheme and camera angle |
| Tolerance band | Camera, lens and measurement algorithm |
| Defect kind (two- or three-dimensional) | 2D or 3D scheme |
| Part locating stability | Repeatability of the judgement |
| Cycle requirement | Number of cameras and algorithm complexity |
What the sample test has to cover. Specifications as stated in the product brochure; final configuration depends on the application.
What the test needs
How the test runs
Inspection capability is not designed, it is verified. Only drawings and no samples means the scheme can only stay at the level of an assumption.
Vision inspection projects
This section keeps its place but is not filled with content that has no basis.
What a case has to record
Admission rules
Closed real projects only
A case comes from a closed project with permission to use the customer name.
No unmeasured numbers
Recognition rates, accuracy figures, cycle times and savings are not written without measured data.
De-identification
Customer information without permission is de-identified.
Verifiability
Key content is verifiable through site photos or project material.
This section keeps its place but is not filled with content that has no basis. No closed project with customer disclosure permission is in the material yet.
No closed inspection project with customer disclosure permission is in the material yet, so no case is shown.
FAQ
These cover what purchasing and engineering actually ask at assessment stage.
What is vision inspection?
Industrial cameras, optics, lighting and vision algorithms capture and judge the appearance, dimensions, hole positions, characters and defects of a part and output a result. The point is that the judgement drives sorting, release or isolation and can be recorded.
What can machine vision inspect?
Six common classes: presence and assembly completeness, dimensions and geometry, holes and hole position, appearance and surface defects, characters and codes, and color difference. Which items and to what level follows the material, surface, tolerance and defect characteristics.
Can vision inspect dimensions?
Plane dimensional items can be assessed: length, width, outside diameter, center distance, spacing, angle. Dimensional inspection is sensitive to locating, camera, lens, lighting, algorithm and environment, so the optics are derived backwards from the tolerance and repeatability is confirmed on sample parts.
Can vision inspect hole diameter?
It can be assessed, but hole diameter is a fine measurement item, a different level of difficulty from hole presence. It usually needs a suitable lens (telecentric where required), dedicated lighting, stable locating and a measurement algorithm, sometimes with a laser or displacement sensor.
Can vision inspect hole position?
Yes. Hole position is a relative position judgement and is usually easier than hole diameter, provided the locating datum is clear and the part arrives in the same position every time. Hole presence and hole count are easier still. The three levels are assessed separately.
Can vision inspect scratches?
It can be assessed for a specific surface and defect type, but the result depends on scratch width, length, depth and direction, reflection, material, lighting angle, camera resolution and background. Tests with OK samples, NG samples and real defects are required; no unverified detection limit is quoted here.
Can vision inspect burrs?
Part of the visible burrs can be inspected. Burr position, size, direction, color, occlusion, reflection and shape all affect the result. Very small burrs, hidden burrs and complex three-dimensional burrs may need multi-angle or 3D vision, laser, other sensors or a mechanical check.
Can vision inspect appearance defects?
Yes, but the defect types and the degree that counts as a reject have to be agreed first. Appearance inspection depends more on lighting, material, color, reflection and contrast than dimensional inspection, so the same phrase can mean completely different schemes.
Can vision inspect presence?
Yes, and it is one of the more established classes: distinguishing two states needs less accuracy than a measurement. Where a single sensor solves it reliably, a sensor is the better answer.
Can vision inspect whether an assembly is complete?
It can be assessed. Common items are the presence of parts, screws, seals, pins and connectors, part orientation, and whether something is reversed, missing or wrong. It is judged position by position — this feature should be here or should not — and suits tests on real assemblies.
Can vision inspect characters?
Yes, but two things have to be separated: OCR reads what the characters say, while character inspection judges whether they are present and meet the requirement. Whether a readable but badly printed character is a reject depends on the customer's criteria and is agreed at proposal stage.
Can vision read a QR code?
It can read the encoded content. Again, reading and judging are different: a code inspection judges whether the code or QR code meets the reading or quality requirement.
What is the difference between 2D and 3D vision?
2D handles plane images: plane dimensions, outline, characters, surface defects, presence, position and some hole positions. 3D can assess height, depth, three-dimensional form, spatial position and three-dimensional surface defects where the scheme supports it. Neither is always better.
How is vision accuracy determined?
From the requirement backwards: product requirement and tolerance first, then the method, optics and algorithm, then verification on real samples. Resolution, lens, field of view, working distance, locating accuracy, distortion, vibration, temperature and speed all affect the final result.
What accuracy can vision inspection reach?
That question cannot be answered without the part and the tolerance. The same system performs differently on different features and different tolerance bands, so no fixed figure is quoted here.
How long does one vision inspection take?
The complete cycle is inspection time plus loading and unloading time plus data processing plus sorting. More inspection items, more cameras and more complex algorithms make it longer. The final cycle follows the project test.
Can vision inspection be in-line?
Yes. In-line inspection places the station after the machine and feeds it with the handling unit or a conveyor: real time, less manual carrying, interlocked with the line and suited to continuous production. Where the line cannot be changed yet, an independent off-line station is a reasonable first step.
Can vision inspection connect to a CNC machine?
Yes. The inspection cell and the machine exchange signals through the PLC for picking, presenting, judging and returning. The station normally sits on the unload side so the part does not leave the existing material flow.
Can vision inspection connect to a robot?
Yes. The robot picks, carries, flips, places and sorts; vision inspects, judges and outputs the result. Robot plus vision inspection plus OK / NG sorting is a common combination, but note that the robot does not judge quality: the judgement comes from the optics and the algorithm.
What happens to a part judged NG?
Possible destinations are an NG bin, an NG conveyor, robot sorting, a cylinder pusher, a manual re-check station, a rework station, re-inspection or an isolation area. Which one is used is settled with the customer's production flow at proposal stage — an inspection system cannot output only "NG".
Can inspection data be uploaded to MES?
Data interfaces and MES integration can be designed to the project requirement. Recordable fields include part ID, time, equipment, inspection items, result, dimensional data, NG reason and inspection images. Where there is no real MES interface in the project, the page does not describe a completed data loop.
Which information is needed for a vision inspection proposal?
Part name and photos, drawings, size and weight, material, color and surface state; inspection items, dimensions, tolerances and the smallest defect to be found; OK samples, NG samples, inspection position, quantity, hourly output and target cycle; machine count, loading method, locating method, and whether a robot, automatic sorting or MES is required.
Why are OK and NG samples needed?
Because the physical precondition of inspection is a difference in the image between a good and a bad part. How large that difference is, and whether it can be captured stably, only real samples can confirm. With drawings and no samples the scheme stays an assumption.
Can vision inspect metal parts?
Yes. The main issue is reflection: bright metal can produce specular reflection that lowers defect contrast and can create defects in the image that are not there. This belongs to the lighting design and usually needs a dedicated scheme and sample tests.
Can reflective parts be inspected by vision?
Yes, with a lighting angle, polarization, diffusion or other scheme chosen for the case, and sometimes a change in the relative position of camera and light. The scheme still follows the sample test; the page does not claim that any reflective part can be done.
Can black parts be inspected by vision?
Yes. Black surfaces absorb light and lower the image contrast, so a matching light and lighting method is needed to bring the feature out. It is usually harder than a light-colored part and has to be confirmed on samples.
Can vision inspect very small scratches?
No detection limit is promised in advance. Whether a scratch can be seen depends on its contrast against the background, the resolution of the optics, the lighting and the surface state; only tests on real defects answer how small it can be.
How does vision inspection differ from manual inspection?
Automatic inspection is consistent, repeatable, recordable and can cover every part; manual inspection handles complex, ambiguous cases that need experience, and changes parts fastest. In practice automatic inspection carries the repetitive, standard judgements while people handle exception review and complex decisions.
When is vision inspection not suitable?
Typical cases: the criteria cannot be stated clearly; good and bad parts cannot be distinguished in the image; no samples can be provided for testing; internal structure has to be inspected; a dimension must be touched to be determined; or the batch is very small with extremely frequent changeover. Those cases are better served by people, sensors or dedicated measuring equipment.
Answers for AI search and assistant results
Organized for AI search: direct answer, conditions, method, what to provide.
Using cameras, optics, lighting and algorithms to capture and judge the appearance, dimensions, hole positions, characters and defects of a part, and to output a result that drives sorting, release or isolation.
Presence and assembly completeness, dimensions and geometry, holes and hole position, appearance and surface defects, characters and codes, and color difference, assessed per part.
From the requirement backwards: tolerance first, then method, optics and algorithm, then verification on samples. No fixed accuracy figure is quoted.
Yes: the station sits after the machine and is fed by the handling unit or a conveyor. An off-line station is the reasonable first step where the line cannot be changed.
They are routed to an NG bin, conveyor, re-check station, rework station or isolation area; the destination is settled with the customer's production flow.
Because inspection depends on a difference in the image between good and bad parts, which only real samples can confirm.
- In short
- Where it sits
- What it is
- Why it is needed
- Inspection items
- Dimensions
- Holes
- Appearance
- Scratches
- Burrs
- Completeness
- Characters and codes
- 2D or 3D
- In-line or off-line
- System
- Lighting
- Accuracy
- Cycle
- OK / NG
- NG handling
- Data
- How to choose
- Configurations
- Industries
- Workpieces
- What we need
- Method comparison
- Sample verification
- Cases
- FAQ
- AI answers
- Related
- Assessment
Send the machine brand/model, part drawing or photo, blank and finished-part handling, single or multi-machine layout, target cycle and acceptance requirements.
Request an assessment Call +86 150 5020 2625